TINY TITAN
Ultra-miniature 95mm humanoid robot built as a Guinness World Record attempt (concluded). Reverse-engineered the proprietary WitMotion binary protocol over UART and BLE Nordic UART Service, creating custom Python drivers published to PyPI.
- Year
- 2024
- Height
- 95 mm
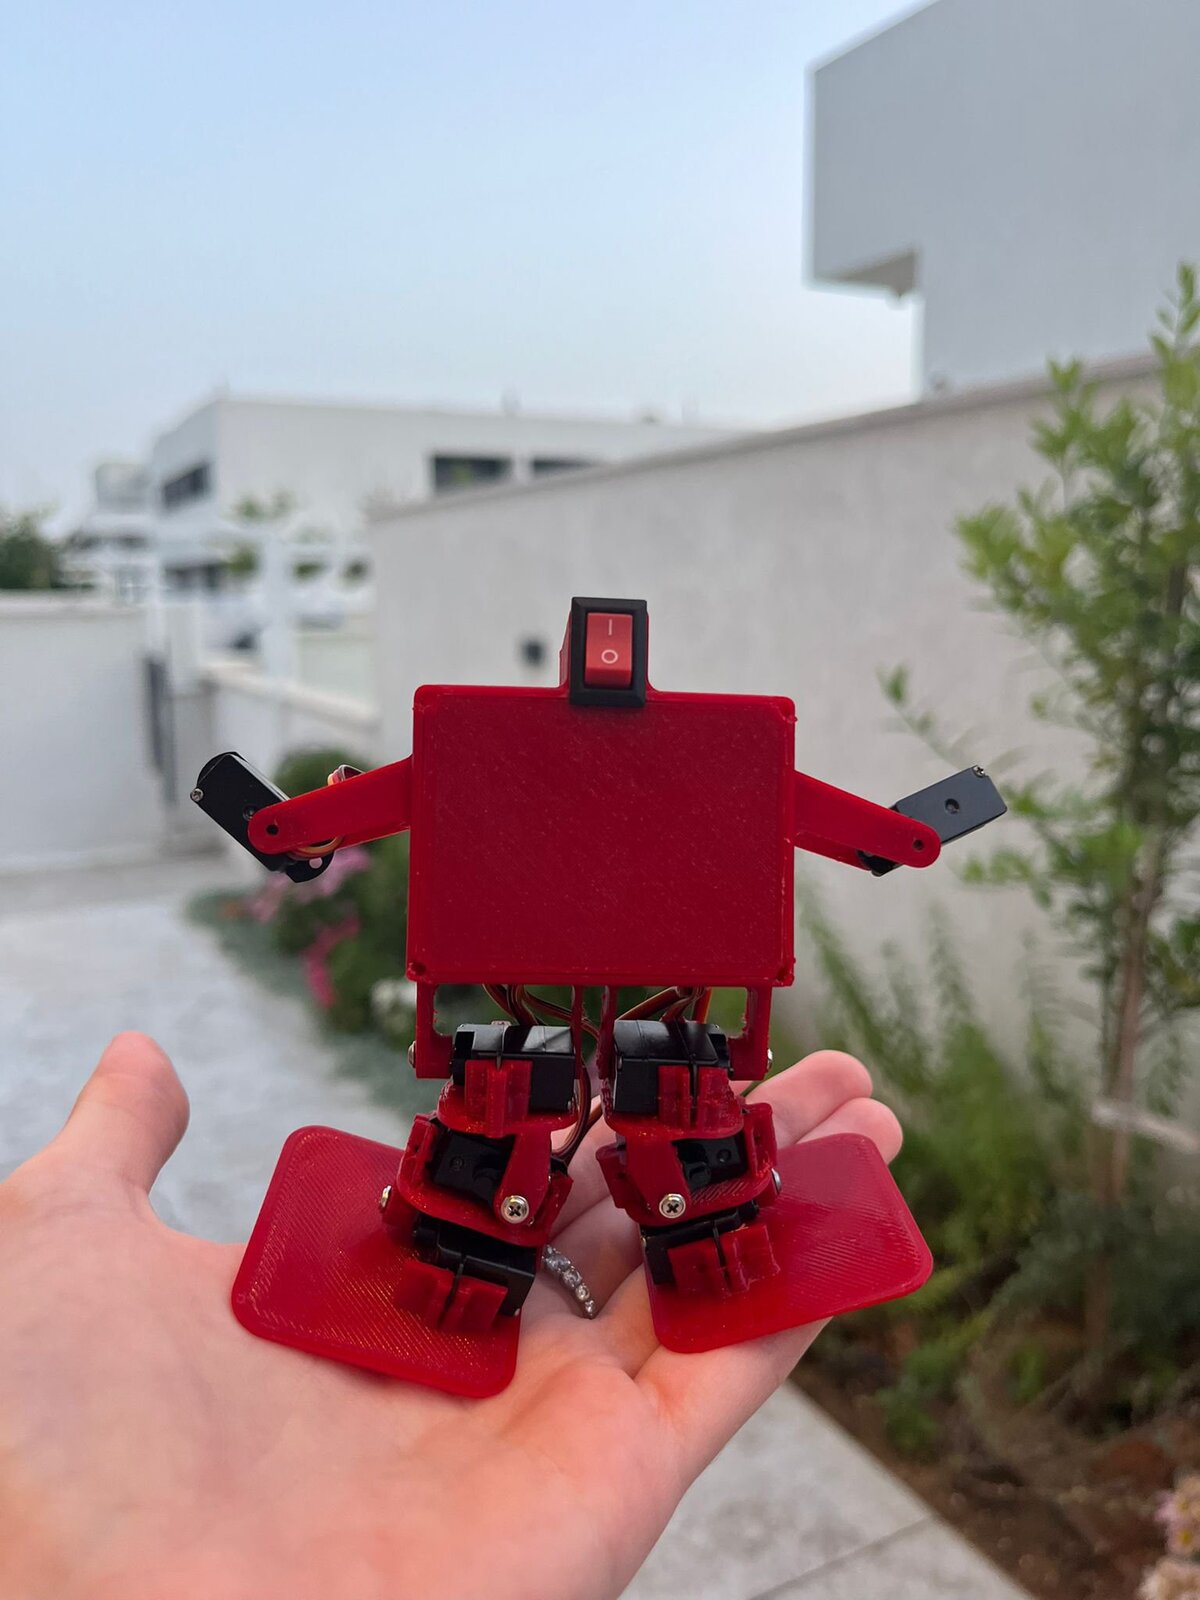
95MM TINY TITAN, HAND-HELD FOR SCALE
GUINNESS WORLD RECORD ATTEMPT, 95MM HUMANOID (CONCLUDED)
Behind the project.
Designed and built to challenge the Guinness World Record for the smallest humanoid robot (then 141mm; at 95mm it was 32% smaller, but a 57.676mm robot claimed the record before verification concluded - attempt concluded, no record held). Powered by 2g sub-micro servos and an all-in-one WitMotion 16-channel Bluetooth PWM driver board stepped up from dual 200mAh 1S LiPo cells. When vendor software proved inadequate and restricted, reverse-engineered the serial protocol by packet sniffing, identified the 5-byte motor command packet, and bypassed Android restrictions by reverse-engineering Nordic UART Service (NUS) over BLE on iOS. Authored and published two open-source Python drivers on PyPI enabling full wireless teleoperation.
Project media.
34 photos & media · Tap to expand
Under the hood.
- Height
- 95 mm
- Controller
- WitMotion 16CH BLE PWM Board
- Power Subsystem
- 2x 200mAh 1S LiPo + Mini 5V Boost
- Protocol
- 5-byte binary packet over Nordic UART BLE
- Libraries Published
- Witmotion16chServoDriverV2, NordicUARTSerialDriver
What came out of it.
- Guinness World Record attempt for the smallest humanoid robot (then 141mm): 95mm, 32% smaller - concluded when the record moved to 57.676mm before verification completed.
- Reverse-engineered proprietary binary UART protocol via serial hex packet sniffing.
- Implemented a polymorphic Python communication module matching PySerial for serial and BLE transparency.
- Custom 3D-printed chassis with tight tolerances and wide footprint feet for balance stability.
- Featured on Hackaday and Hackster.io.